FROM ROBOTICS KITS TO DESIGNING MY OWN HARDWARE
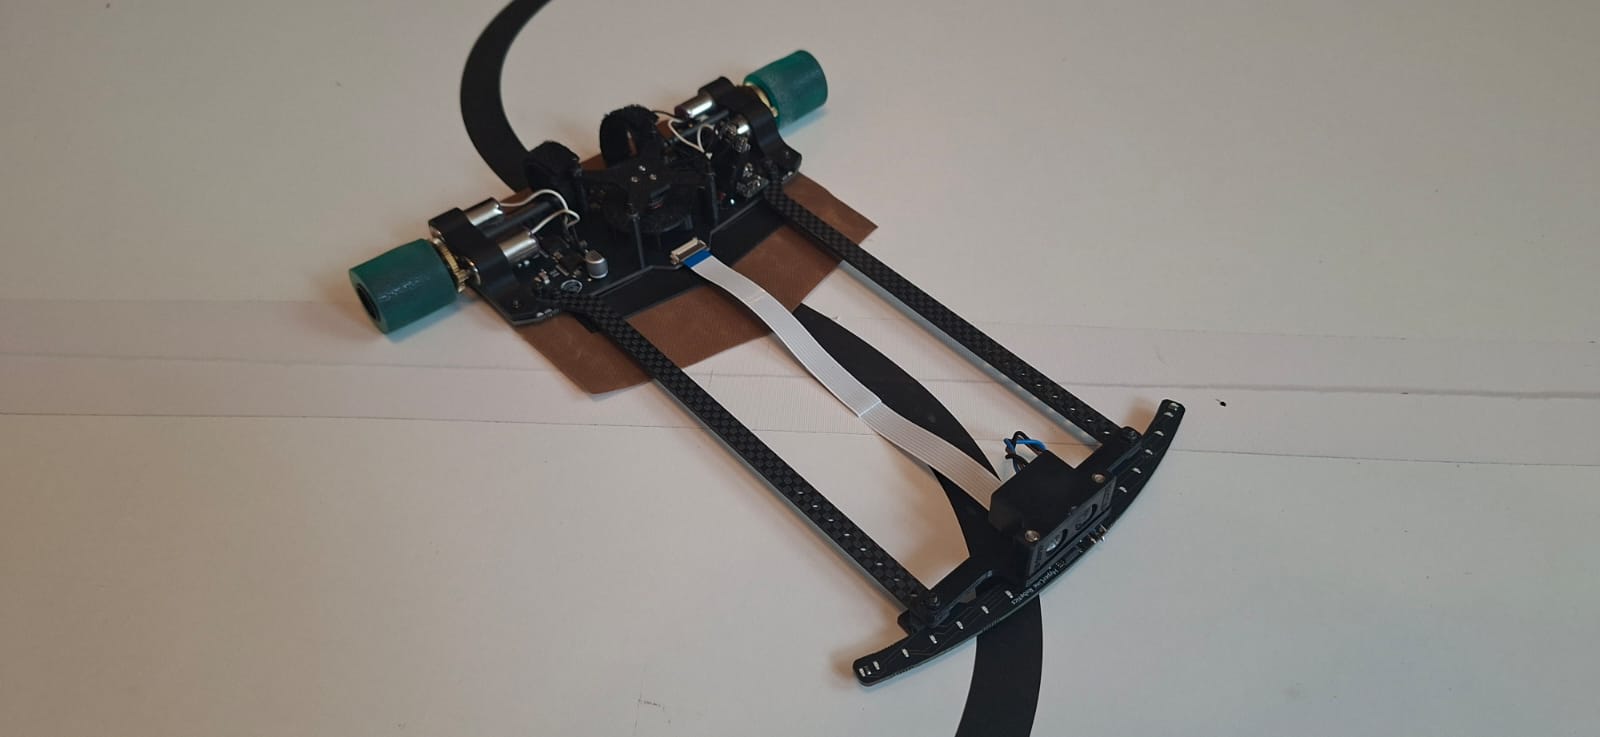
When I started robotics in 2019, almost everything came from a kit. My work was to understand the parts and assemble them.
Eventually I reached their limits. A sensor was too slow, a controller lacked pins, or a robot became too large because the hardware was not designed for the task. That pushed me toward electronics and PCB design.
My first boards simply connected existing modules and cleaned up wiring. Gradually I replaced modules with my own circuits and learned voltage regulation, motor drivers, microcontrollers, buses, sensors and power distribution.
Designing the whole system
The same happened in mechanics. Instead of adapting a robot around available components, I designed mounts, gears, carbon parts and chassis around the robot. Eventually that included custom motors and pinions.
Today I can begin with an idea and work through electronics, mechanics, firmware, software and testing. I still use off-the-shelf parts when they make sense, but I no longer feel limited by them.