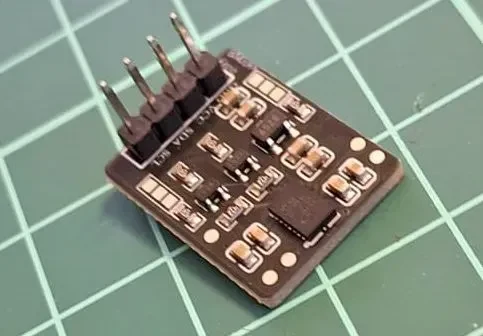
Stable motion data for mobile robots
GYROSCOPE · ACCELEROMETER · I²C
This compact module is built around the BMI088 IMU to provide high-precision rotation data and stable acceleration measurements for mobile robots such as autonomous RC cars. The device combines a high-performance gyroscope and low-noise accelerometer as separately optimized sensing elements, maintaining stable output during vibration and sudden movement.
Designed for clean measurements
- Power-supply filtering reduces noise affecting sensor output
- Short, clean I²C traces support stable communication
- Optimized ground layout minimizes measurement interference
- Centered sensor placement reduces rotational bias
- Separate optimized sensing elements improve vibration stability
Applications
- Autonomous RC cars
- Self-balancing robots
- Inertial navigation systems
- Robotics motion tracking and research
Open-source files
The published project includes schematic and PCB layout files, a bill of materials, and a basic firmware example for sensor initialization.
Open design files ↗